Minghao Ning
Minghao Ning
Ph.D. Candidate, University of Waterloo
Autonomous driving, robotics, perception, sensor fusion, motion planning, and cooperative infrastructure autonomy.
I am a Ph.D. candidate in Mechanical and Mechatronics Engineering at the University of Waterloo, advised by Prof. Amir Khajepour and co-supervised by Prof. Ehsan Hashemi. My research focuses on building deployable perception and planning systems for autonomous vehicles and mobile robots, especially under adverse weather, occlusion, network latency, and real-world deployment constraints.
Research Focus
Selected Systems and Project Highlights
Fielded autonomous vehicle
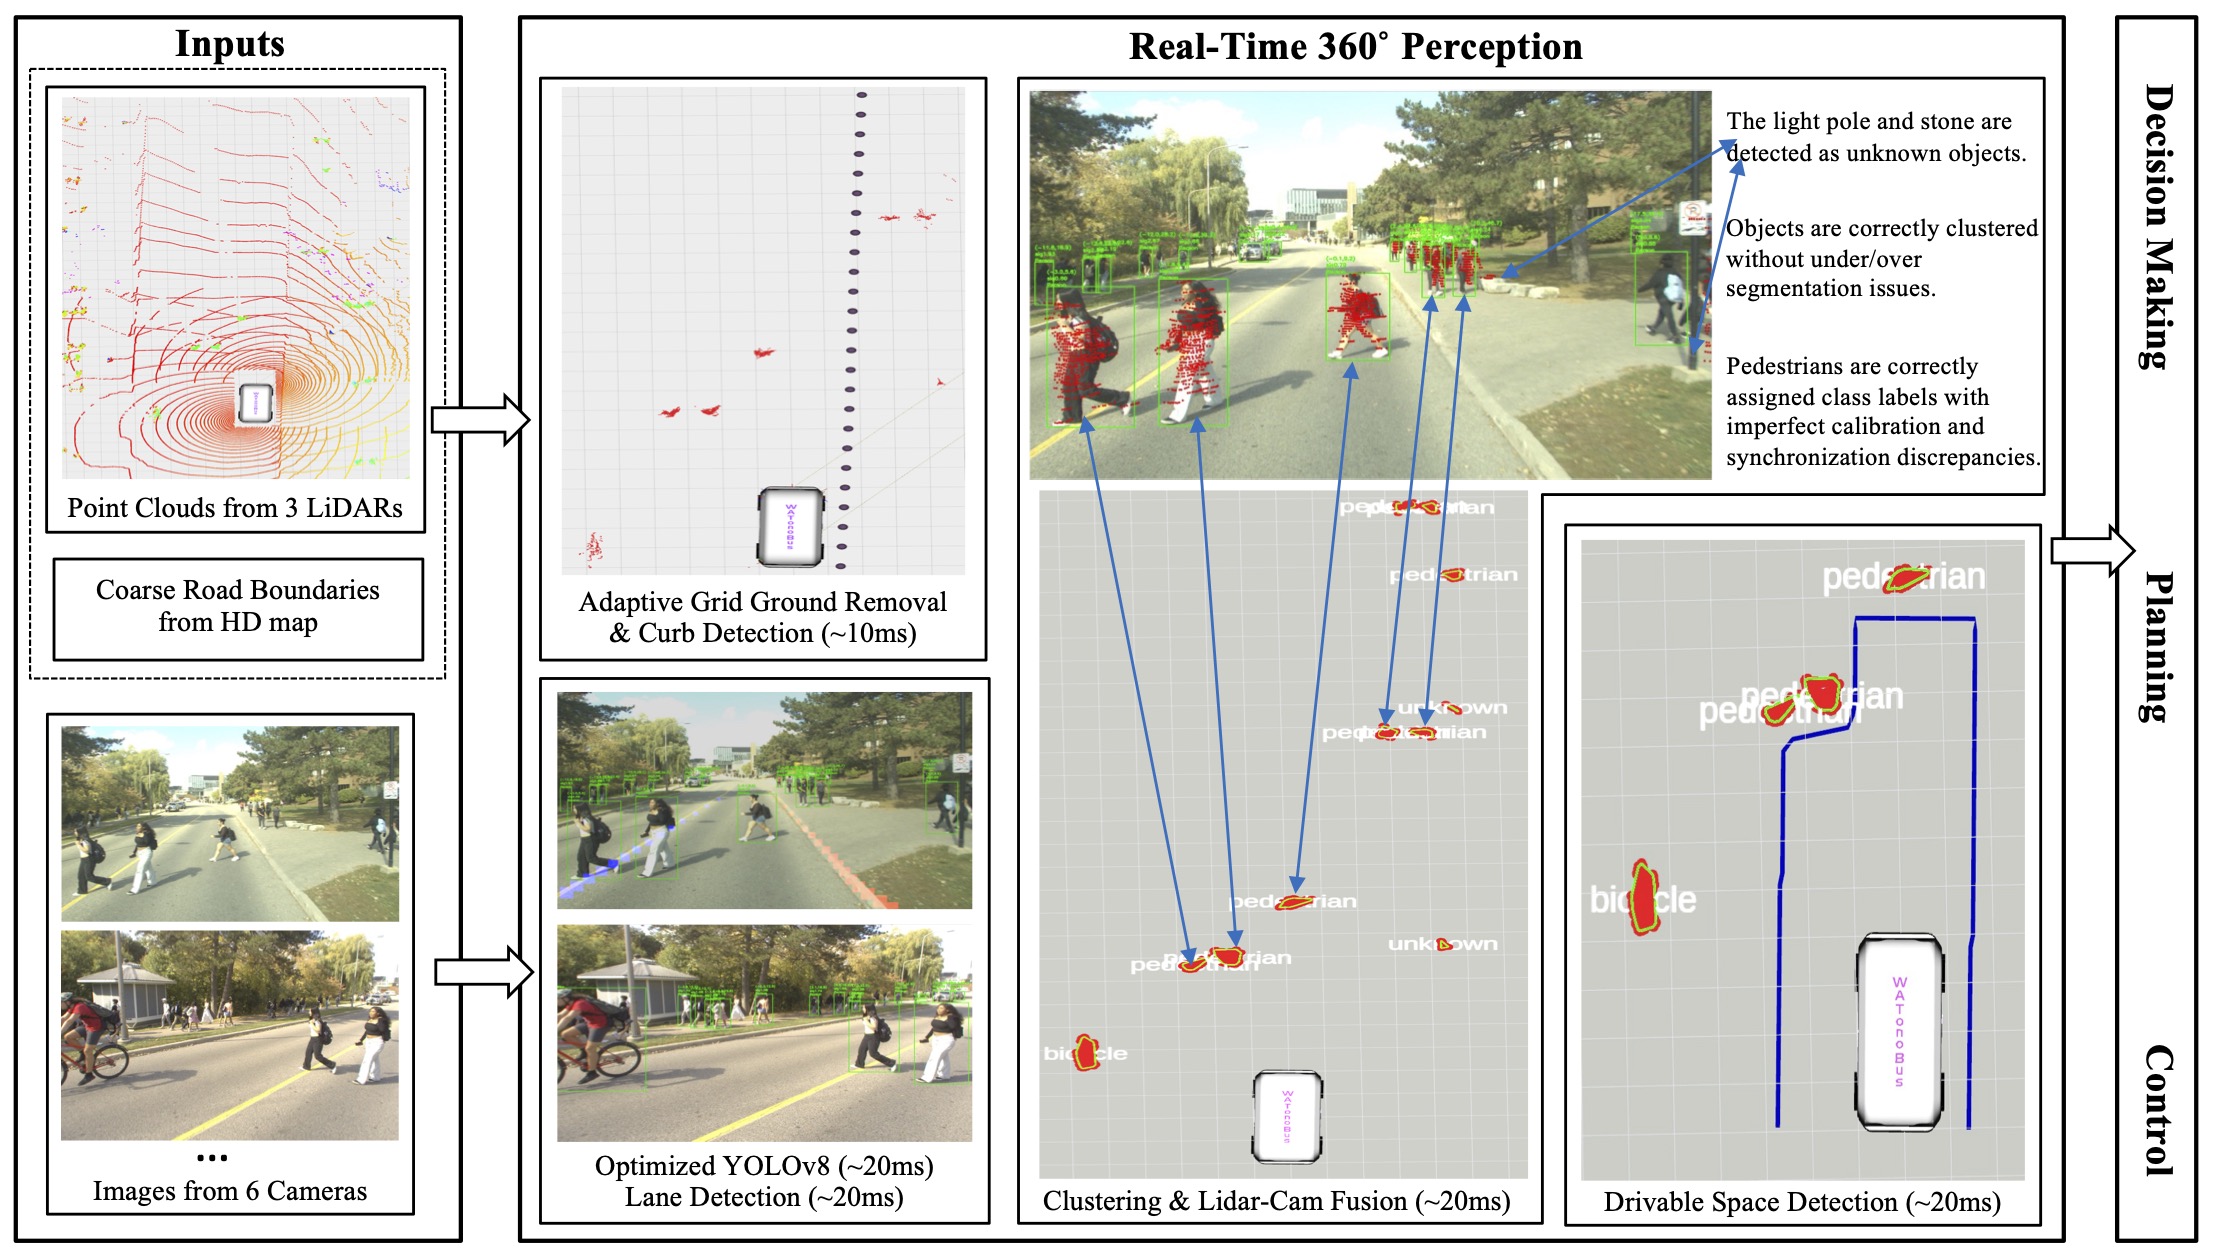
WATonoBus autonomous shuttle
Led perception development for a full-scale autonomous shuttle, including LiDAR-camera-HD map drivable-space estimation and field-test validation in complex road scenes and Canadian winter conditions. Also led the transition from a custom in-house autonomy stack toward an Autoware-based next-generation platform.
Supporting links: drivable-space code, UWaterloo News, MathWorks, ESV.
Roadside infrastructure network
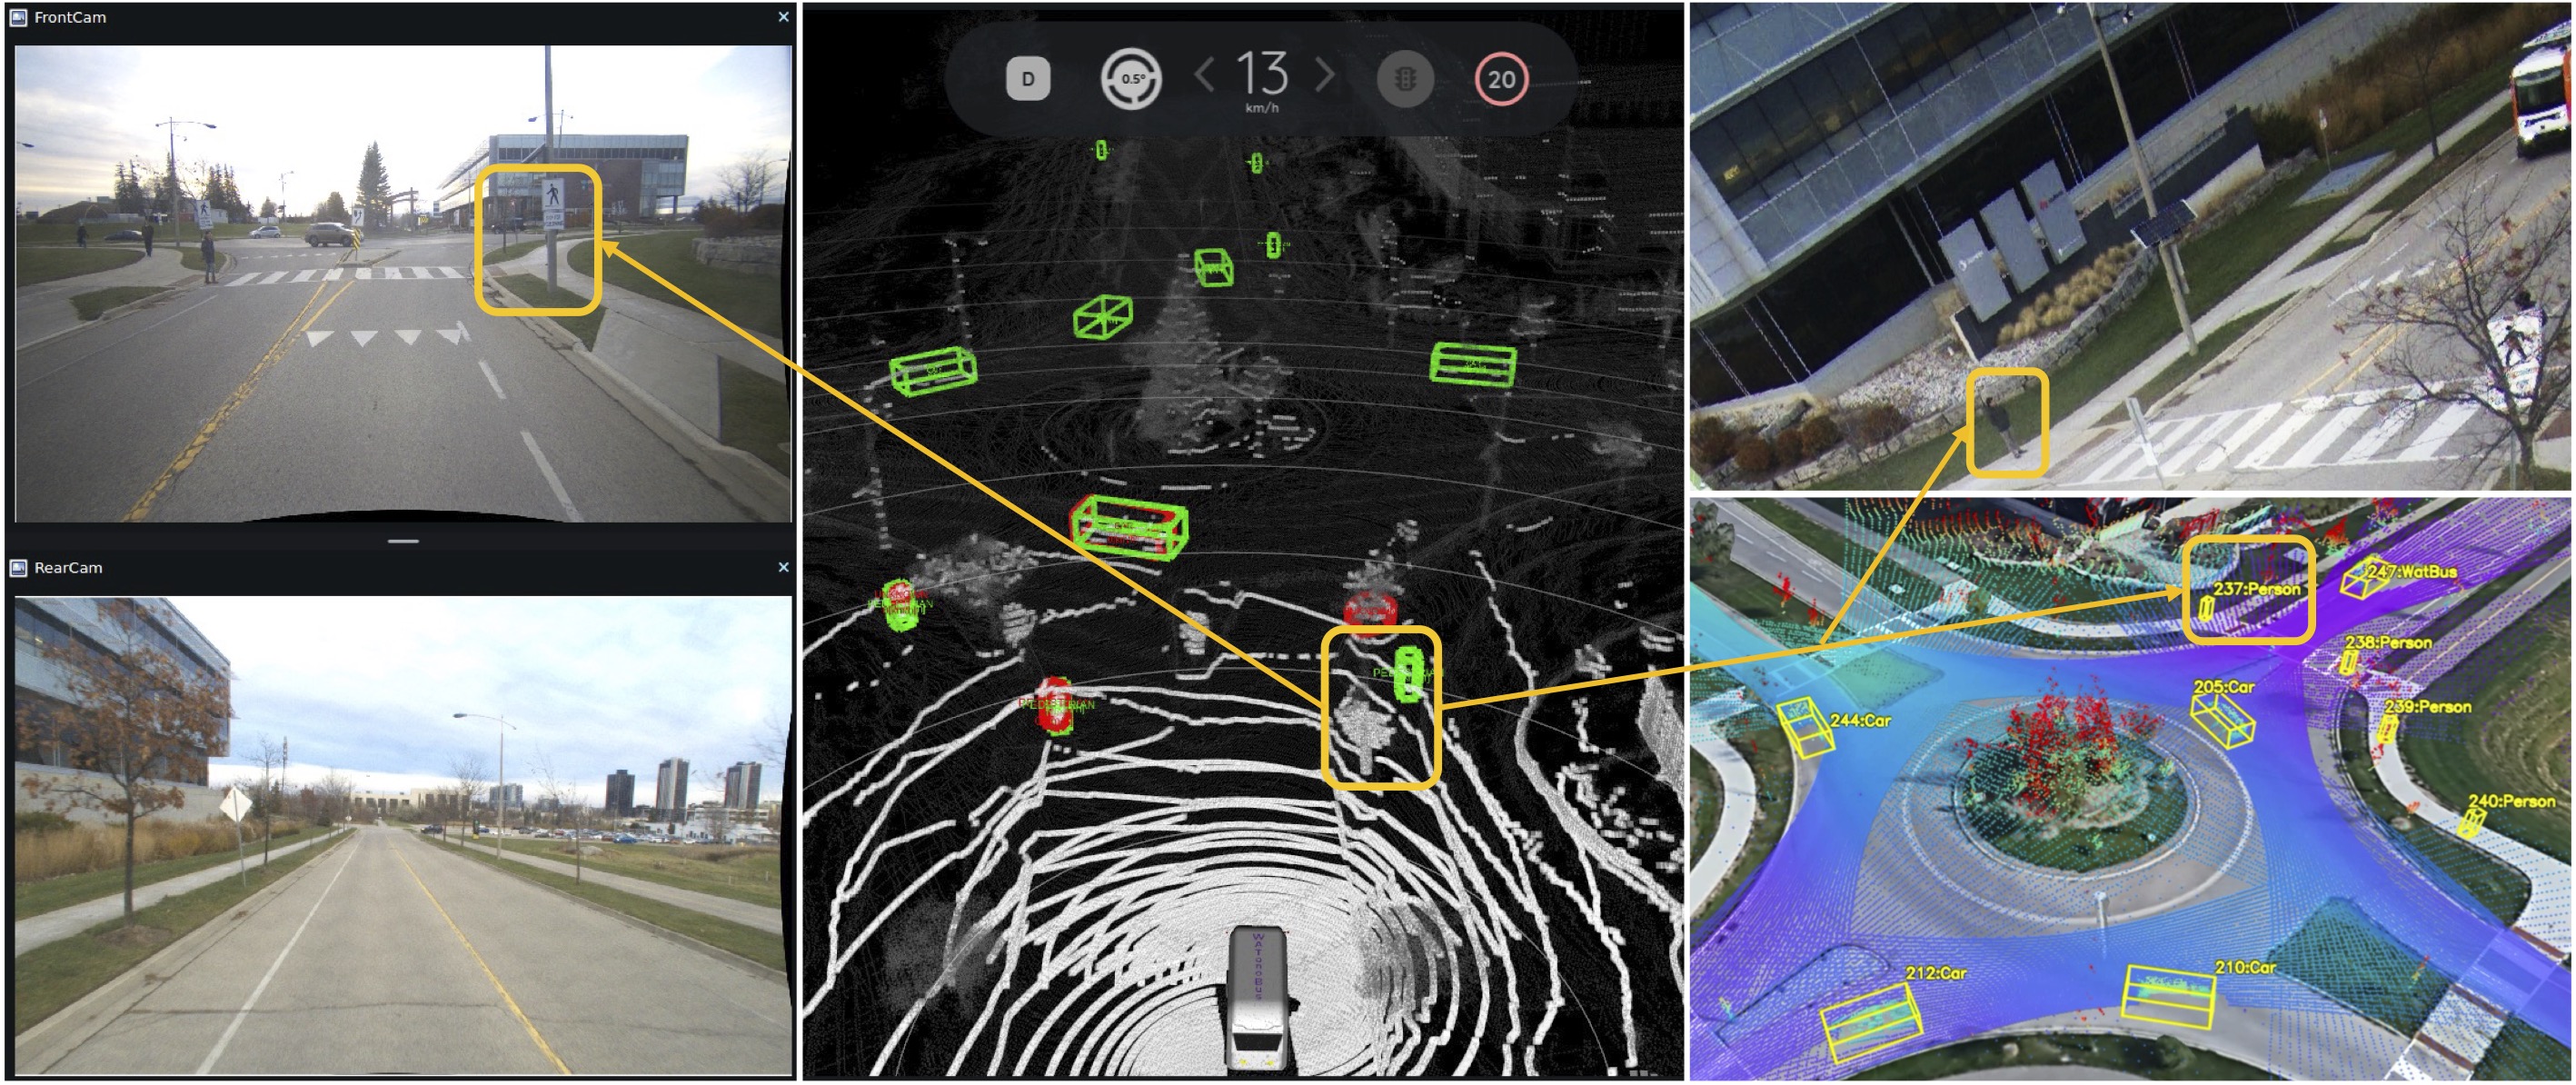
CoInfra cooperative infrastructure perception
Designed and deployed a 14-node roadside testbed with cameras, LiDAR, edge computers, and 5G/Wi-Fi for adverse-weather traffic perception. The system supports calibration, synchronization, cloud-side fusion, globally consistent 3D tracking, and public data/code release.
Supporting link: arXiv preprint.
Edge-cloud autonomy framework
Cloud-based Autonomous Mobility (CAM)
Developed an edge-cloud mobility framework that connects infrastructure sensing to autonomy services for shared scene understanding, safety warnings, connected autonomous driving, and robot mobility across outdoor and indoor environments.
Supporting link: arXiv preprint.
Indoor robot mobility
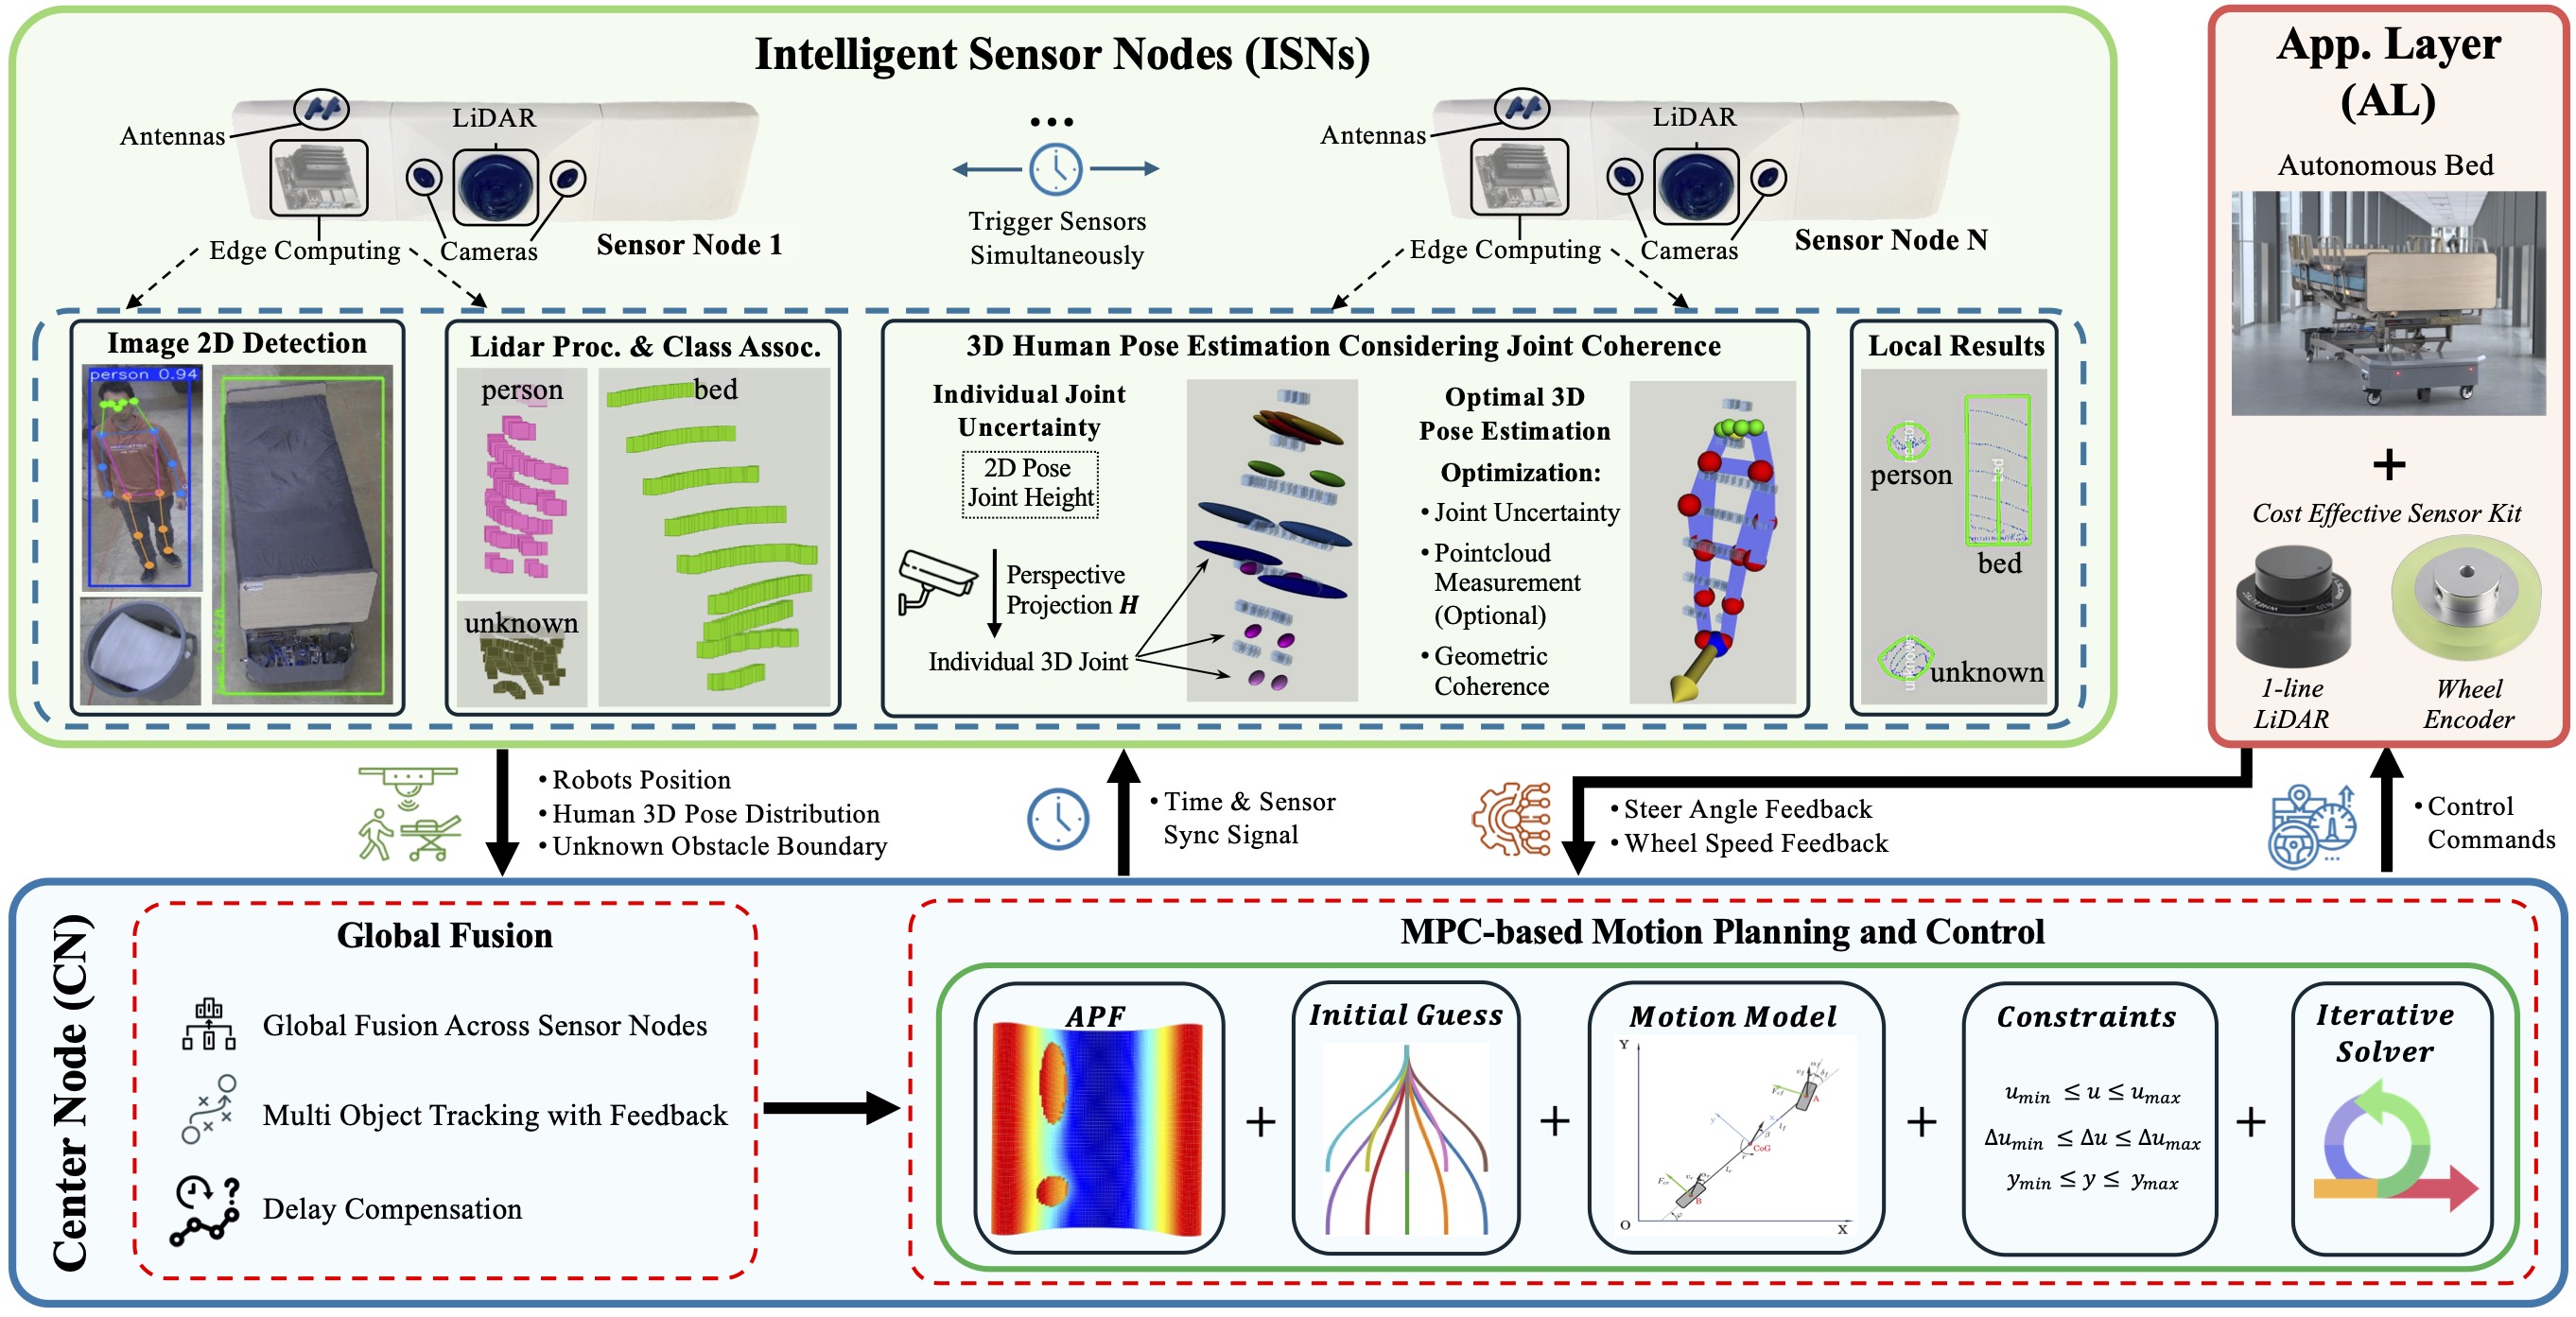
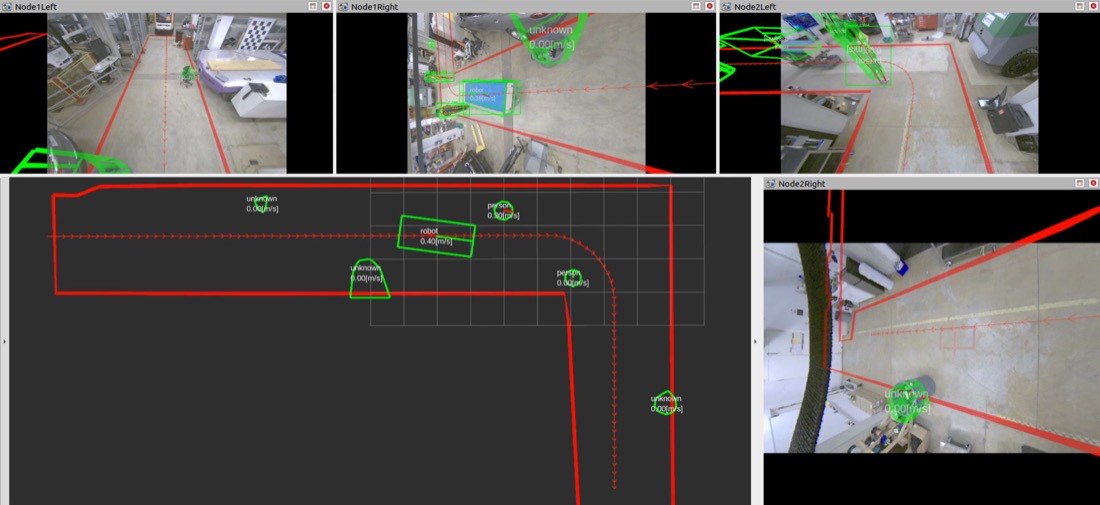
Indoor cooperative perception and robot mobility
Built ceiling-mounted cooperative sensing for occlusion-heavy indoor spaces, including uncertainty-aware 3D human pose estimation and delay-aware tracking. The perception output feeds closed-loop MPC on a real medical-bed robot platform.
Supporting links: SAP-CoPE code, indoor code, UWaterloo News.
Selected Publications
- CoInfra: A Large-Scale Cooperative Infrastructure Perception System and Dataset in Adverse Weather. Under review at Transportation Research Part C, 2026. [project] [arXiv] [code]
- Real-World Deployment of Cloud Autonomous Mobility System Using 5G Networks for Outdoor and Indoor Environments. Under review at IEEE Intelligent Transportation Systems Magazine, 2026. [project] [arXiv]
- SAP-CoPE: Social-Aware Planning using Cooperative Pose Estimation with Infrastructure Sensor Nodes. Revised manuscript under review at IEEE Transactions on Automation Science and Engineering, 2026. [project] [arXiv] [code]
- A Novel Motion Planning for Autonomous Vehicles Using Point Cloud Based Potential Field. IEEE Transactions on Vehicular Technology, 2024. [project] [DOI]
- An Efficient Approach to Generate Safe Drivable Space by LiDAR-Camera-HD Map Fusion. IEEE International Conference on Intelligent Transportation Systems, 2024. [project] [DOI] [code]
- Enhancing Indoor Mobility with Connected Sensor Nodes: A Real-Time, Delay-Aware Cooperative Perception Approach. IEEE International Conference on Intelligent Transportation Systems, 2024. [project] [DOI] [code]
See the full Publications page and my Google Scholar profile for the complete and most up-to-date publication list.